Welcome to the official repository for the PixieBots’ robot, a top-five finalist in SLRC 2025 (Sri Lanka’s Largest Robotic Competition), University Category. This repository showcases our engineering journey, robust software, and mechanical innovations designed to tackle a complex, multi-faceted challenge under a demanding 30-minute time limit.
Our robot features a compact, robust mechanical design (24 cm x 18 cm) and a custom 4-Degrees of Freedom (DoF) robotic arm. It’s engineered for precision, adaptability, and autonomous operation in dynamic, unpredictable environments.
- 4DOF Robotic Arm: Shoulder rotation, elbow flexion, wrist rotation, and gripper actuation powered by precision servos.
- Integrated Storage: Two onboard compartments for color-classified ping-pong balls.
- Durable Chassis: Designed for stability across ramps, muddy regions, and confined passages.

Our robot’s intelligence is built on a robust, modular codebase, enabling it to interpret and react to its surroundings with high accuracy and reliability.
- Line Following & Junction Detection: Tracks both solid and colored lines, recognizes junctions for grid-based navigation.
- Dotted Line Following: Advanced tracking for segmented paths.
- Obstacle Detection: Proactively avoids obstacles using real-time sensor data.
- Ramp Navigation: Detects inclines (e.g., 20-degree ramp) and dynamically adjusts speed for safe traversal.
- Color-Based Classification: Detects and sorts ping-pong balls by color using calibrated sensors.
- Barcode Reading: IR sensor-based barcode detection for environmental awareness.
- Encoder PID Control: Maintains precise straight-line movement using PID algorithms and high-resolution encoders.
- Precise Object Handling: Picks and places balls and boxes with accuracy.
- Automated Sorting: Stores classified objects in dedicated compartments.
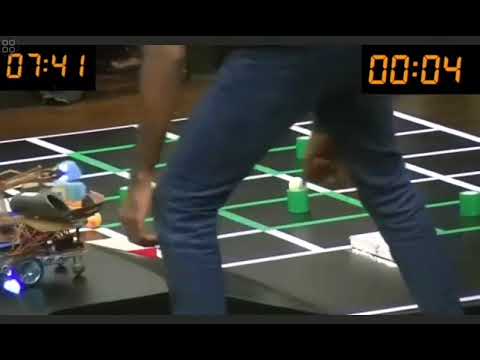
Our software is designed for reliability, flexibility, and real-time performance.
- Comprehensive Error Handling: Detects hardware faults, sensor anomalies, and recovers gracefully from unexpected events.
- Fail-Safe Routines: Watchdog timers and safety interlocks ensure safe operation at all times.
- Task-Based Modules: Each competition objective is encapsulated for rapid adaptation before/during the event.
- Subsystem Abstraction: Independent modules for locomotion, manipulation, and sensing allow parallel development and debugging.
- Event-Driven Architecture: Asynchronous event loops respond instantly to environmental changes and judge commands.
- Subsystem Communication: Efficient message passing coordinates the arm, drive system, and sensors for multi-step tasks.
A centerpiece of our robot, the 4DOF arm, enabled success in manipulation and sorting tasks.
- Joints: Shoulder rotation, elbow flexion, wrist rotation, gripper actuation.
- Actuators: High-precision servos for smooth, controlled movement.
- Workspace: Optimized kinematic chain for object pickup, placement, and interaction.
- Kinematics: Forward and inverse kinematics for accurate end-effector positioning.
- Feedback: Encoders and current sensors for closed-loop force and position control.
- Programmability: Supports custom trajectories and variable-speed operations for delicate and fast tasks.
- Task Execution: Essential for picking, sorting, and placing objects under time pressure.
- Contribution: Key to completing color classification, ball collection, and storage tasks.
The SLRC 2025 finals presented us with eight distinct objectives to be completed within a tight 30-minute window. Our robot excelled in:
- Ping-Pong Ball Collection: Grabbing balls from cylindrical components in a grid.
- Color-Based Classification: Sorting balls by color with high sensor precision.
- Muddy Region Navigation: Maneuvering through tough terrain and obstacles.
- Ramp Ascent & Descent: Traversing steep ramps with robust control.
- Confined Passage Navigation: Precise steering through narrow, walled passages.
Our seamless transitions between environments and complex multi-step execution propelled us to the top five.
- Source code: Algorithms, sensor integration, and control systems
- Technical documentation: Arm schematics, system architecture, setup instructions
- Competition media: Photos, videos, and performance highlights
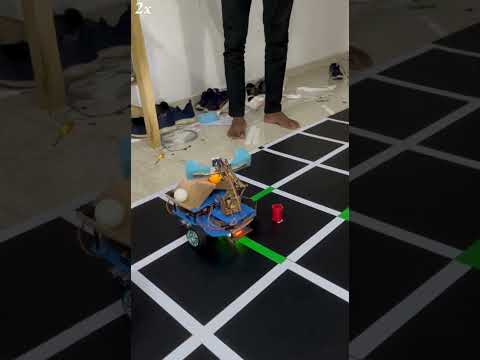
Watch our robot's performance in the official grand finale broadcast:
Performance Period: 5:56:00 to 6:12:00
Full broadcast: SLRC 2025 Finals Live Broadcast
We hope this repository provides valuable insights into our engineering process and inspires future robotic endeavors!
Questions or feedback? Feel free to open an issue or pull request.